Blog

Latest news, competition preparations, and technical articles from our team.

Godot 4
Software Team May 2026

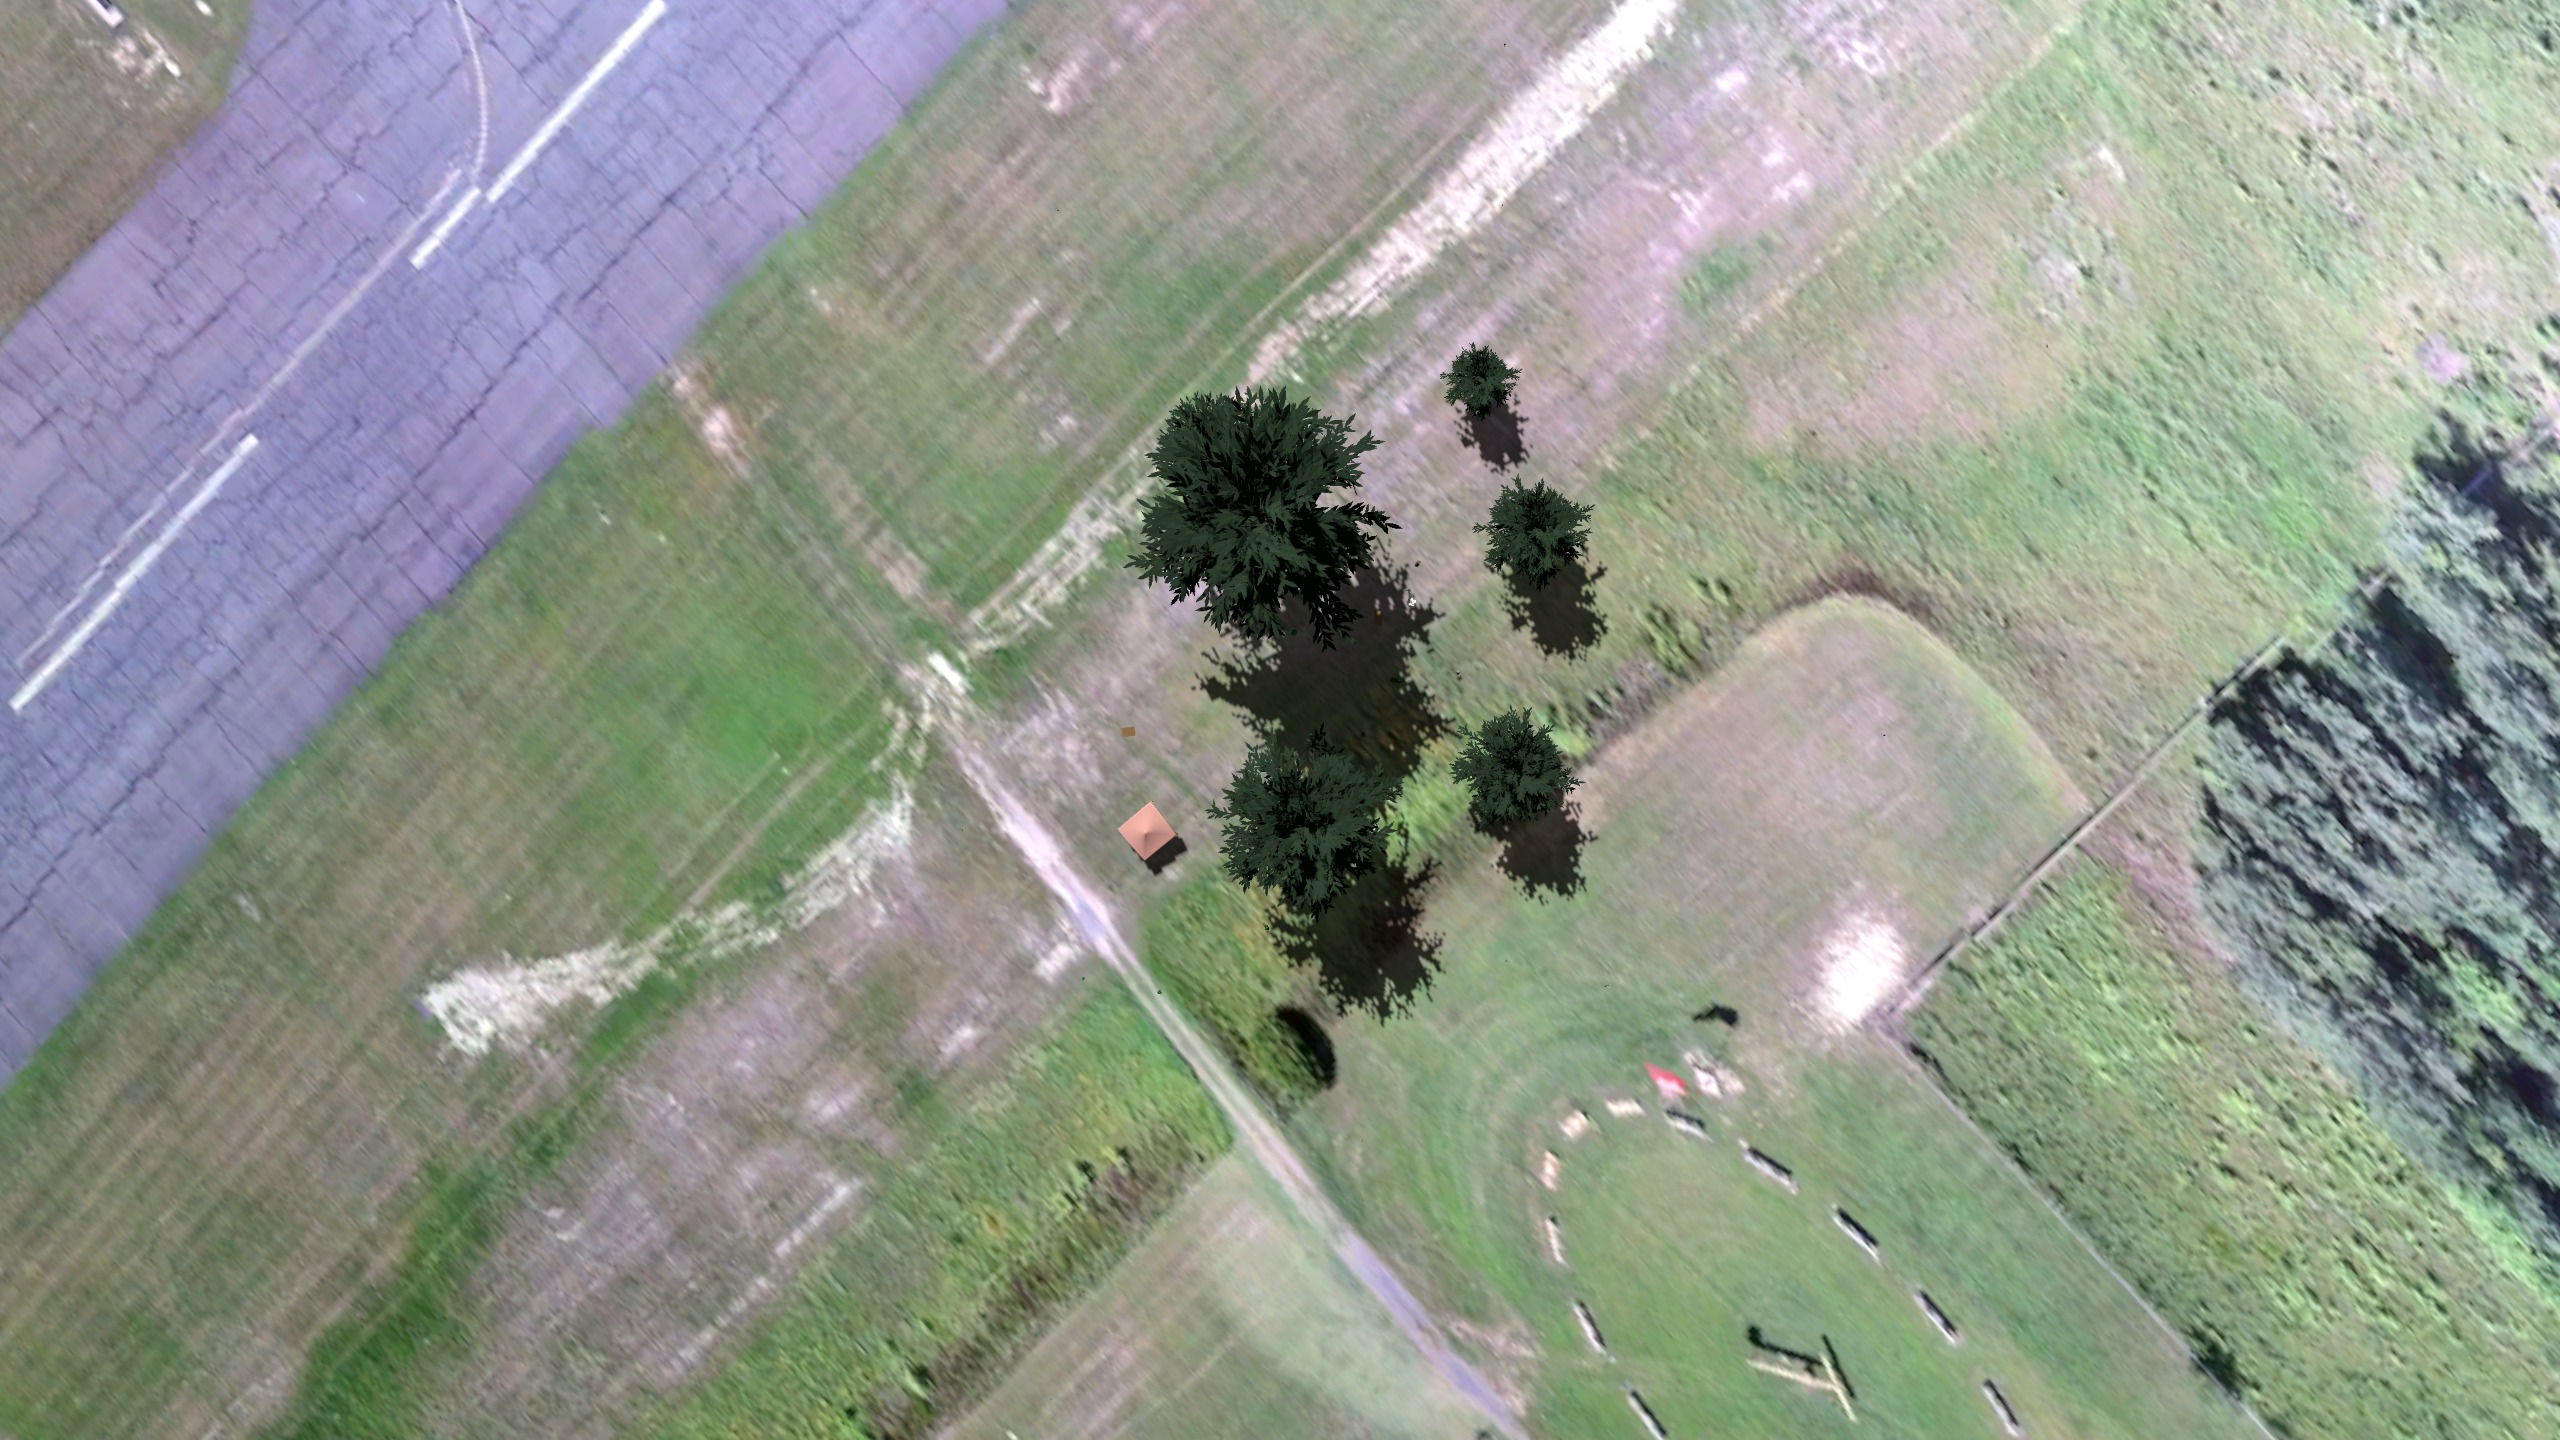
Building a 4K Synthetic Dataset Generator in Godot 4 for the SUAS Competition

Generating high-quality training data for computer vision models can be a massive bottleneck, especially for specialized drone missions. Read how we solved this for the SUAS competition using Godot 4.

Read More →
Risk Mapping
Software Team May 2026

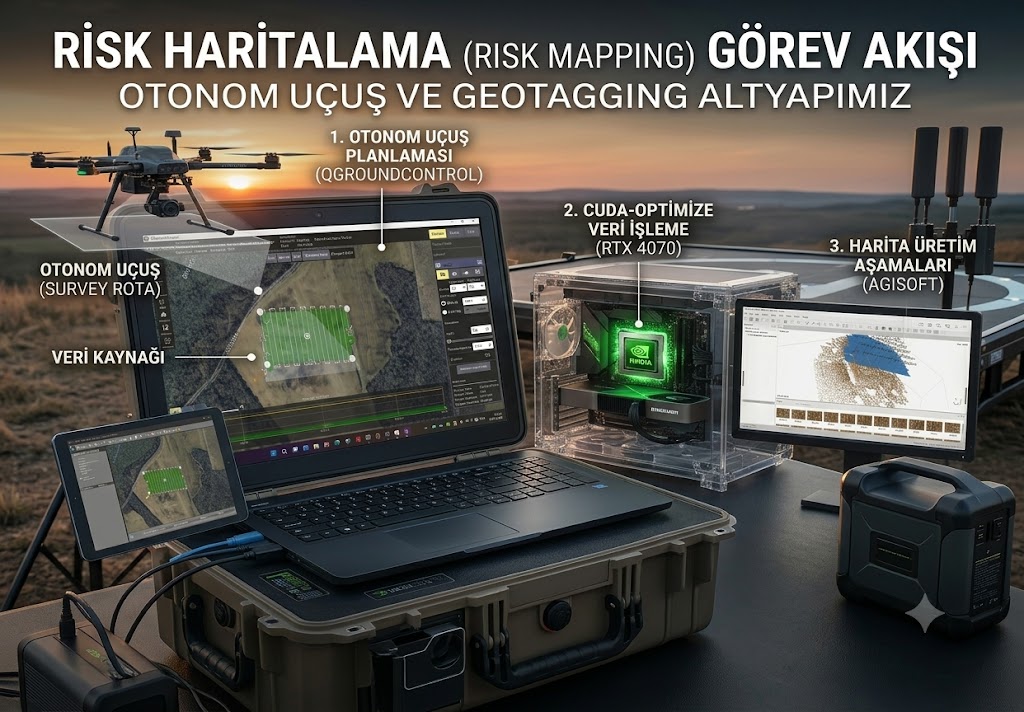
Risk Mapping Mission Flow: Our Autonomous Flight and Geotagging Infrastructure

In one of the most critical stages of the competition, the "Risk Mapping" mission, we need to generate a high-resolution and flawless 2D satellite map...

Read More →
Hawk Dive
Software Team July 2026

V3 Hawk Dive: Human-Operator Assisted Autonomous Targeting

We have successfully completed 'V3 Hawk Dive,' the final architecture of our flight and target approach systems, with ArduPilot SITL and Gazebo Sim integration...

Read More →
MPCC Interface
Software Team May 2026

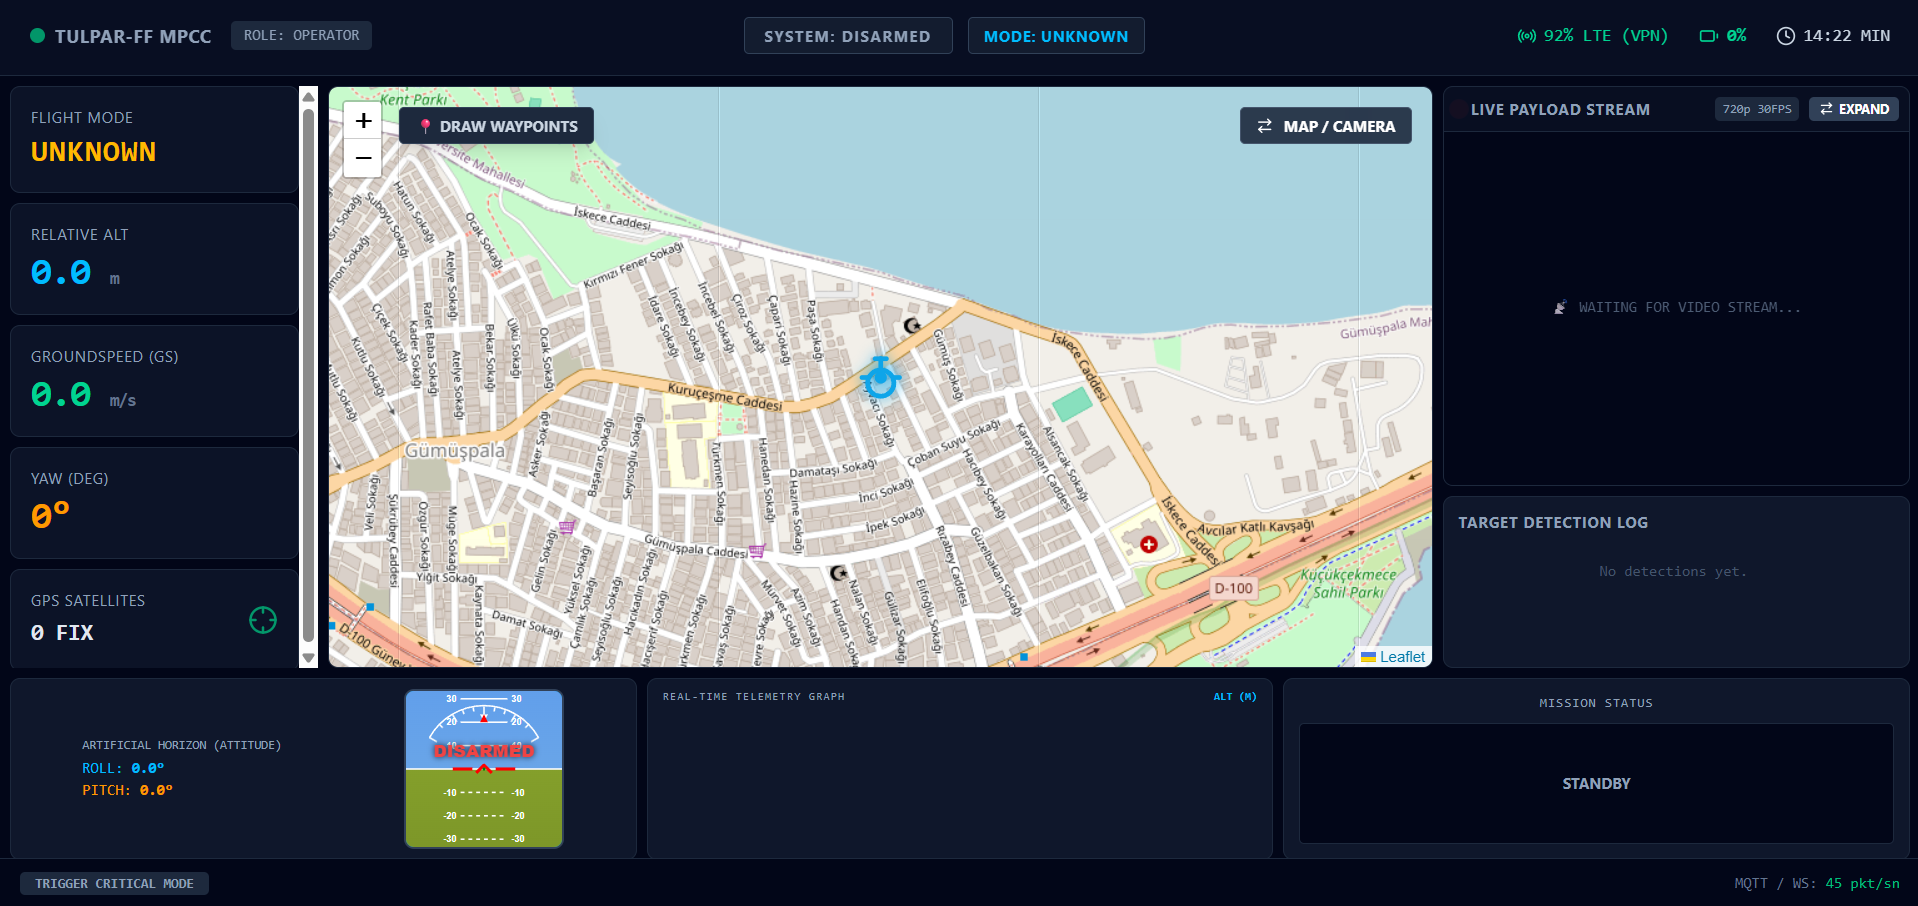
TULPAR-FF MPCC: Operator-Centric and Custom Developed Ground Control Interface

Half of the success in autonomous UAV operations lies in the air, while the other half depends on how comfortably and quickly the operator at the ground station can control the system...

Read More →
GCS Failsafe
Test & Simulation Team April 2026

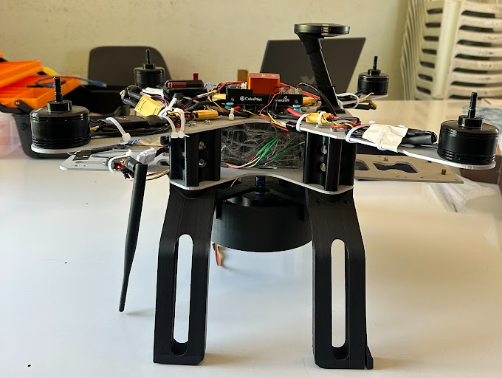
TULPAR-FF Field Diaries: Our GCS Failsafe Solution and Flawless Takeoff Procedures

In line with our SUAS and TEKNOFEST 2026 goals, we are continuing TULPAR-FF's field tests without slowing down. System reliability and instant fault diagnosis in autonomous flights come before everything else for us...

Read More →
Tasarım Stratejimiz
Design Team July 2026

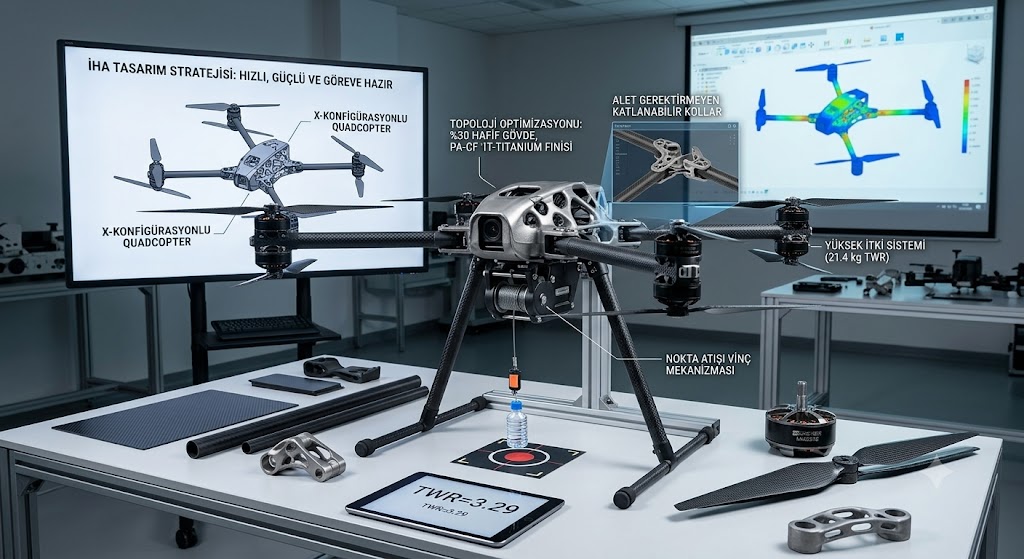
Our UAV Design Strategy: Fast, Powerful, and Mission-Ready

By flawlessly integrating mechanical, electrical, and software subsystems in our project, we developed both a simple and highly reliable Unmanned Aerial Vehicle (UAV) platform...

Read More →